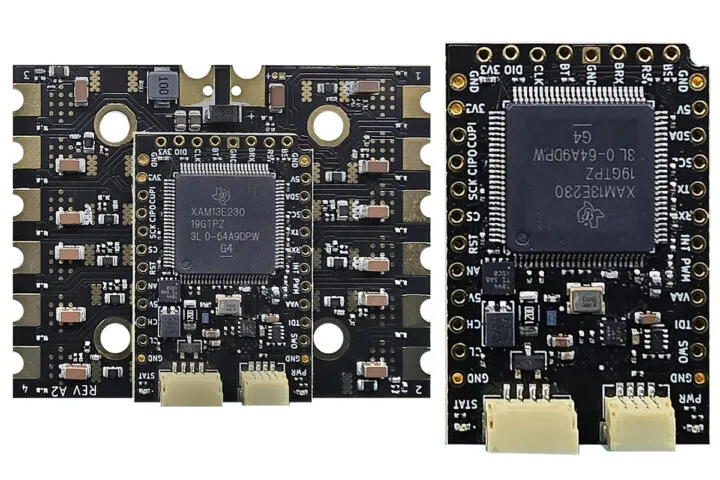
BeagleConnect QuadESC 4-channel BLDC motor controller uses TI’s AM13E23019-based Torque module
BeagleBoard.org has launched the BeagleConnect QuadESC, an open-source 4-channel BLDC motor controller built around the BeagleConnect Torque SoM with TI's AM13E23019 microcontroller.
The BeagleConnect QuadESC is built around the BeagleConnect Torque System on Module (SoM), which features Texas Instruments' 200 MHz AM13E23019 Arm Cortex-M33 microcontroller. This chip includes a trigonometric math unit (TMU) and TinyEngine neural-network accelerator, making it suitable for edge AI applications alongside motor control.
The carrier board supports four three-phase BLDC motor outputs, twelve current and voltage sensing channels, four temperature sensors, and battery voltage monitoring. It also includes an eight-pin flight controller connector with DShot, telemetry, and current reporting signals, along with SWD debugging and a buzzer connector.
Versatile Applications
The Torque SoM can be integrated with custom carrier boards for various applications including robotics, motor control systems, and CAN-connected devices. It provides essential processing, sensing, and communication interfaces, while external hardware handles motor power requirements.
This open-source design offers developers flexibility for creating custom motor control solutions while maintaining compatibility with standard interfaces and protocols commonly used in industrial and robotics applications.
Related
